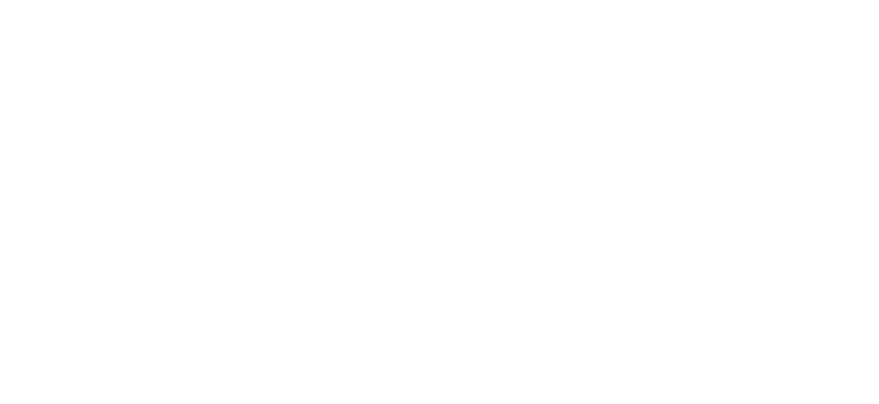
RM-EGB Compact Electric Gripper
The RM-EGB is an all-in-one electric gripper with a built-in controller, designed as a drop-in replacement for pneumatic grippers of the same specification. Gripping force from 10 to 80 N and stroke from 6 to 10 mm are both selectable in steps, chosen directly by an I/O signal combination with no parameter setup required. Built-in adaptive gripping plus empty-grip and workpiece-drop detection; supports Modbus RTU and I/O control.
Manufacturer: RobustMotion | Category: Electric Grippers | Models: RM-EGB-06-6, RM-EGB-06H-16D, RM-EGB-06L-20D

- Direct replacement for same-size pneumatic grippers
- Multiple force settings from 6-85N and multiple stroke settings from 0~10mm
- Triggered by I/O combinations with no setup procedure, simple and easy to use
- Adaptive gripping, empty-grip and workpiece-drop detection

Models and Specifications
| Item | RM-EGB-06-6 | RM-EGB-06H-16D | RM-EGB-06L-20D |
|---|---|---|---|
| Size code | 06 | 06H | 06L |
| Stroke (mm) | 6 | 6 | 10 |
| Gripping force (N) | 10 / 20 / 30 / 40 (4 steps) | 10 / 15 / 35 / 60 (4 steps) | 16 / 30 / 60 / 80 (4 steps) |
| Absolute position (mm) | 0 / 2 / 4 (3 steps) | 0 / 2 / 4 (3 steps) | 0 / 4 / 8 (3 steps) |
| Repeatability (mm) | ±0.02 | ||
| Fastest open / close time (s) | 0.3 / 0.3 | 0.1 / 0.1 | 0.18 / 0.18 |
| Allowable load moment (N·m) | MR 1.36, MP 0.8, MY 0.68 | MR 1.36, MP 0.8, MY 0.68 | MR 2.65, MP 2.35, MY 1.65 |
| Controller | Built-in | ||
| Control (fieldbus) | Modbus RTU | ||
| Control (interface) | I/O control | ||
| I/O interface | 3 inputs (NPN), 3 outputs (NPN) | ||
| Rated voltage (V) | DC24 ±10% | ||
| Rated current (A) | 0.3 | 0.3 | 0.4 |
| Peak current (A) | 0.6 | 0.6 | 0.8 |
| Weight (kg) | 0.22 | 0.22 | 0.32 |
| Dimensions (mm) | 23.5 × 38 × 98 | 23.5 × 38 × 98 | 27.6 × 50 × 108 |
| Operating environment | 0–40°C, 85%RH or less (non-condensing) | ||
| Protection rating | IP40 | ||
Highlighted rows differ between models; values shared by all models are merged into one cell.
Both gripping force and absolute position are selected directly by I/O signal combination — no parameter setup is needed. Gripping force is a reference value measured at 25°C with a tolerance of ±15%.
For full specifications and dimensional drawings, see RM Electric Actuator General Catalogue (PDF).
Model Code
RM-EGB-[size code][version]-[spec]-[cable outlet position]-[cable outlet type & length]-[series]
| Field | Available codes |
|---|---|
| Size code | 06 |
| Version | / (standard), H (high speed), L (standard length) |
| Spec | 6, 16D, 20D |
| Cable outlet position | 1 (side), 2 (bottom) |
| Cable outlet type & length | D0200, D0300 (D = direct cable) |
| Series | ITG, RTU |
I/O Combination Control Signals
Three input signals select motion and force directly by their ON/OFF combination, with no parameter setup; three output signals report position, grip and error states.
Input signals (motion commands)
| No. | IN0 | IN1 | IN2 | Description |
|---|---|---|---|---|
| 1 | OFF | OFF | OFF | Open to limit, force 100% |
| 2 | OFF | ON | OFF | Position to 2 mm, force 100% |
| 3 | OFF | OFF | ON | Position to 4 mm, force 100% |
| 4 | OFF | ON | ON | Open to limit, force 50% |
| 5 | ON | OFF | OFF | Grip to limit, force 100% |
| 6 | ON | ON | OFF | Grip to limit, force 75% |
| 7 | ON | OFF | ON | Grip to limit, force 50% |
| 8 | ON | ON | ON | Grip to limit, force 25% |
Output signals (status feedback)
| No. | OUT0 | OUT1 | OUT2 | Description |
|---|---|---|---|---|
| 1 | OFF | OFF | OFF | In motion |
| 2 | OFF | ON | OFF | Open position reached (no externally gripped workpiece detected, or workpiece dropped) / positioning move completed |
| 3 | OFF | ON | ON | Open position reached and workpiece detected by external grip |
| 4 | ON | OFF | OFF | Grip position reached, no workpiece detected / workpiece dropped |
| 5 | ON | ON | OFF | Grip position reached and workpiece detected |
| 6 | OFF | OFF | ON | Positioning move not completed, force reached 100% |
| 7 | ON | ON | ON | Device error |
Typical Applications
Pick-and-place of small parts
The 6–10 mm stroke covers the outer dimensions of most small electronic parts and connectors, and the minimum 10 N gripping force handles thin workpieces. Force is selected by I/O combination, so a product changeover only requires a different input pattern — no re-parameterisation.
Direct replacement of pneumatic grippers
The mounting interface matches pneumatic grippers of the same specification, so the mechanism usually does not need to be redesigned — only the air tubing and solenoid valve are replaced by a DC24V supply and I/O wiring. The changeover also adds stepped force control and status feedback that pneumatics cannot provide.
Pick-and-place doubling as presence detection
Grip-completed, empty-grip and workpiece-drop each have their own output state, so the handling motion itself confirms whether a workpiece is present — no separate photoelectric or proximity sensor is needed at the station.
Frequently Asked Questions
Can the RM-EGB directly replace an existing pneumatic gripper? Do I need to modify the mechanism?
For equivalent specifications it can be a direct replacement: the mounting interface is designed to match pneumatic grippers, so the mechanism usually does not need to be redesigned. What changes is the control side: where you previously connected the air line and solenoid valve, you now connect a DC24V power supply and I/O signal lines. Because the controller is built in and both force and position are selected directly by I/O combinations, no parameter setup is required; in practice wiring, power-up and operation can be completed in about one minute.
Without parameter setup, how do I specify the gripping force and position on the RM-EGB?
They are selected directly by the ON/OFF combination of 3 input signals (IN0, IN1, IN2), giving eight combinations: all OFF = open to limit, 100% force; IN1 = position to 2mm; IN2 = position to 4mm; IN1+IN2 = open to limit, 50% force; IN0 = grip to limit, 100% force; IN0+IN1 = 75% force; IN0+IN2 = 50% force; all three ON = 25% force. No PC or configuration software is needed.
How do I know whether the gripper has actually picked up the workpiece? Can it detect empty grips or dropped parts?
3 output signals (OUT0, OUT1, OUT2) report seven states: in motion; open position reached (no workpiece detected in outward gripping, or workpiece dropped); open position reached with a workpiece detected in outward gripping; grip position reached but no workpiece detected (empty grip or dropped part); grip position reached with a workpiece detected; positioning move not completed but force has reached 100%; and device error. The pick-and-place motion itself becomes an inspection step, with no additional sensors required.
How do I choose between the three RM-EGB models?
RM-EGB-06-6 has a 6mm stroke, gripping force of 10/20/30/40N (4 steps) and a 0.3 s open/close time, suitable for general pick-and-place. RM-EGB-06H-16D is the high-speed version: same 6mm stroke but open/close time shortened to 0.1 s, with gripping force of 10/15/35/60N. RM-EGB-06L-20D increases the stroke to 10mm, with gripping force of 16/30/60/80N, a 0.18 s open/close time and a higher allowable load moment (MR 2.65, MP 2.35, MY 1.65 N·m). Choose the 06H for speed, and the 06L for a longer stroke or higher gripping force.
Can the RM-EGB grip fragile workpieces such as thin glass?
The lowest force step of the RM-EGB is 10N (RM-EGB-06-6 and 06H-16D) and 16N for the RM-EGB-06L-20D; combined with adaptive gripping, it can handle general thin parts. If the workpiece is more fragile and needs a gripping force below 10N, we recommend the RM-RGM instead (minimum 4N). Gripping force values are measured reference values at 25°C with a tolerance of ±15%, so please confirm the usable force with trial grips on the actual workpiece. When selecting a model, feel free to send us the workpiece material, dimensions and weight for evaluation.
Other Electric Grippers Models
- RM-GB Servo Electric Gripper — The RM-GB servo electric gripper is a drop-in replacement for pneumatic grippers of the same specification, with a stroke of 20~170 mm and a max. gripping force of 65~700 N. It offers very high-speed opening and closing, adaptive gripping, and built-in empty-grip and workpiece-drop detection. The 11 / 17 series are available as ITG integrated versions (built-in controller); separate controller types work with RM-C / RM-CEP / RM-CEM / RM-CEU-55 controllers and support a range of industrial fieldbuses including EtherCAT, PROFINET and EtherNet/IP.
- RM-GB-HF/F Precision Force-Control Servo Electric Gripper — The RM-GB-HF/F is a servo electric gripper in the RobustMotion SoftForce® precision force-control series (also called a force-control electric gripper or force-control servo gripper). It adds a force sensor to the RM-GB platform for closed-loop force control with real-time gripping force feedback, while capturing force–position–time data to generate process curves. Strokes are 20 / 40 / 60mm, the closed-loop gripping force range spans 0.2–98.9N depending on sensor range, and repeatability is ±0.05mm. With position hold on power loss and power-loss detection, it is suited to transfer, assembly, soldering and inspection of workpieces such as chips, dies and flexible flat cables. Used with the RM-CEPF / RM-CEMSF controllers, it supports EtherCAT, PROFINET, CC-LINK and Modbus TCP / RTU.
- RM-MGBD-HF Precision Force-Control Miniature Electric Gripper — The RM-MGBD-HF is a two-jaw miniature electric gripper in the RobustMotion SoftForce® precision force-control series (also called a force-control electric gripper). With force-control accuracy down to ±0.01N, it performs closed-loop force control with real-time gripping force feedback while capturing force–position–time data to generate process curves. Stroke is 13mm, repeatability ±0.02mm and fastest open / close time 0.25 s; the closed-loop gripping force range spans 0.02–15N depending on sensor range. It is suited to pick-and-place of fragile, high-value workpieces such as packaged chips, micro optical lenses and precision components. Used with the RM-CEUF / RM-CEMF controllers, it supports EtherCAT, PROFINET, CC-LINK and Modbus TCP / RTU.
- RM-RGM Servo Rotary Electric Gripper — The RM-RGM servo rotary electric gripper combines gripping and unlimited 360° rotation in a single actuator. It offers an adjustable stroke of 0~32 mm, gripping force of 4~100 N, a max. rotation speed of up to 2160°/s, position repeatability of ±0.02 mm and rotation repeatability of ±0.05°. With a built-in controller and Modbus RTU support, it suits assembly and inspection stations that need to pick, place and rotate parts at the same time.
A key-spec comparison of every model, with selection notes and FAQs, is in the Electric Grippers selection guide.
More from RobustMotion
- MagiFloater® Planar Maglev Conveyor — MagiFloater® is a modular planar maglev conveyor system that builds flexible production lines from a combination of stators and movers. Movers levitate above the stator surface and move omnidirectionally in 6D — X, Y, Z plus rotation about three axes — with position accuracy of ±0.02mm and a levitation height of 0.5–5mm. Stators are interconnected via Ethernet and support a range of industrial communication protocols, allowing direct connection to host computers, robots or other motion control mechanisms. Applications include biopharmaceutical, cosmetics and food, 3C and lithium battery, and semiconductor and optics production lines.
- RM-NPLA Miniature Slide-Table Electric Cylinder — The RM-NPLA miniature slide-table electric cylinder (also called an electric linear actuator or compact electric cylinder) is compact with repeatability of ±0.005mm. Strokes of 30mm and 50mm are available, and depending on the lead it offers combinations of max. speed from 50 to 300mm/s and max. thrust from 30 to 210N. It supports industrial fieldbuses including Modbus RTU, EtherCAT, Modbus TCP, PROFINET, EtherNet/IP, CC-LINK and CANopen, and is suited to precision assembly and inspection stations.
- RM-NPLA-HF Precision Force-Control Miniature Slide-Table Electric Cylinder — The RM-NPLA-HF is a miniature slide-table electric cylinder in the RobustMotion SoftForce® precision force-control series (also called a force-control electric cylinder or force-control linear actuator). A built-in force sensor enables closed-loop force control with real-time force feedback and force-control accuracy down to ±0.01N, while force–position–time data is captured to generate process curves. Size code 10 models offer 30 / 50mm stroke and ±0.005mm repeatability; size code 16 models offer 75 / 150mm stroke. Depending on sensor range and lead, the closed-loop force range spans 0.02–294.9N. Used with the RM-CEUF / RM-CEMF controllers, it supports EtherCAT, PROFINET, CC-LINK and Modbus TCP / RTU.